I am an engineer and researcher working at the intersection of Cyber-Physical Systems (CPS), Robotics, Real-Time Control, and Mechatronics. I hold a dual M.Sc. in Autonomous Systems from KTH Royal Institute of Technology (Sweden) and Polytech Nice Sophia, Université Côte d'Azur (France), backed by a B.Tech in Mechanical Engineering from NITK Surathkal.
Most recently, I completed my master's thesis and R&D work at Scania (TRATON Group) in Sweden, developing machine learning models and closed-loop simulator-based driver-support policies over 20,000+ hours of commercial battery-electric truck telemetry. Previously, I spent 5.5 years as a researcher at the Indian Institute of Science (IISc) in the Centre for Networked Intelligence (CNI) and DESE, leading projects across bounded-latency robotic teleoperation, in-network computing on P4 programmable switches, Time-Sensitive Networking (TSN), and rapid mechatronic prototyping.
Featured Projects and Builds
Selected engineering and research builds across robotics, programmable networking, haptics, and mechatronics. Click any project for architecture details, schematics, and demonstrations.
RoboTwin
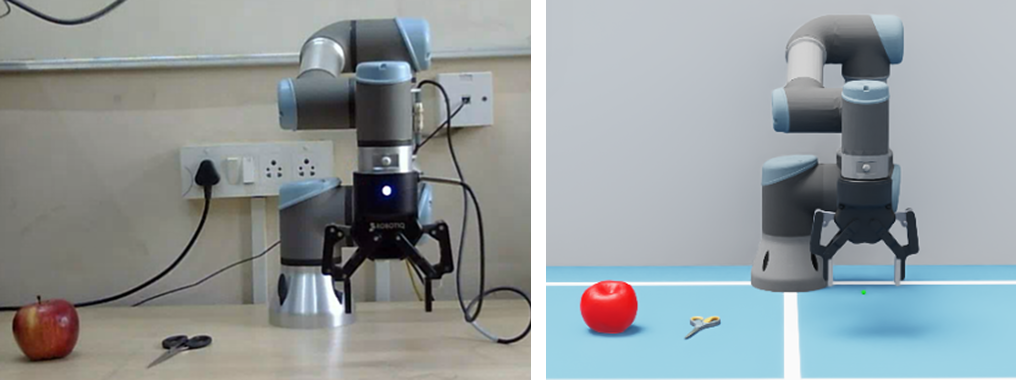
A dual-digital-twin teleoperation framework synchronizing physical manipulators with GPU-accelerated NVIDIA Isaac Sim and ROS2. The operator-side twin provides zero-latency haptic feedback via Geomagic Touch, while the remote twin validates safe operating bounds before physical execution. Using RealSense RGB-D vision, YOLOv8 object detection, and SSIM discrepancy tracking, it streams semantic state updates—cutting network bandwidth by 25x and reducing NASA-TLX cognitive workload.
View Preprint →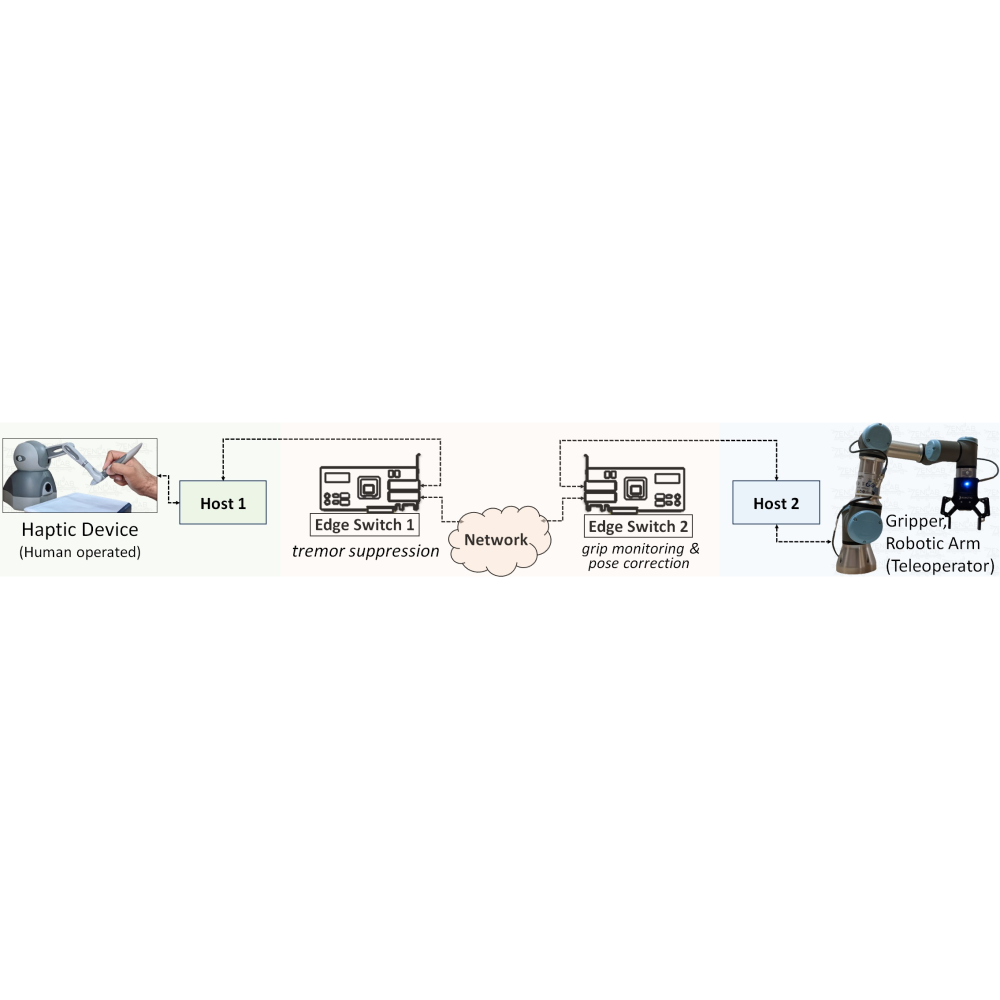
EdgeP4
In-network computing framework running directly on P4-programmable switches and Netronome Agilio SmartNICs to overcome host-side OS jitter in wide-area robotics. Offloads tremor suppression and closed-loop pose correction into the network data plane, slashing feedback latency below 100 µs and cutting wide-area network traffic by up to 99.9%. Validated on an intercity tactile CPS testbed across 400 km with a UR3 manipulator. Awarded Best Paper at IEEE INFOCOM CNERT 2024.
Code → Project Details →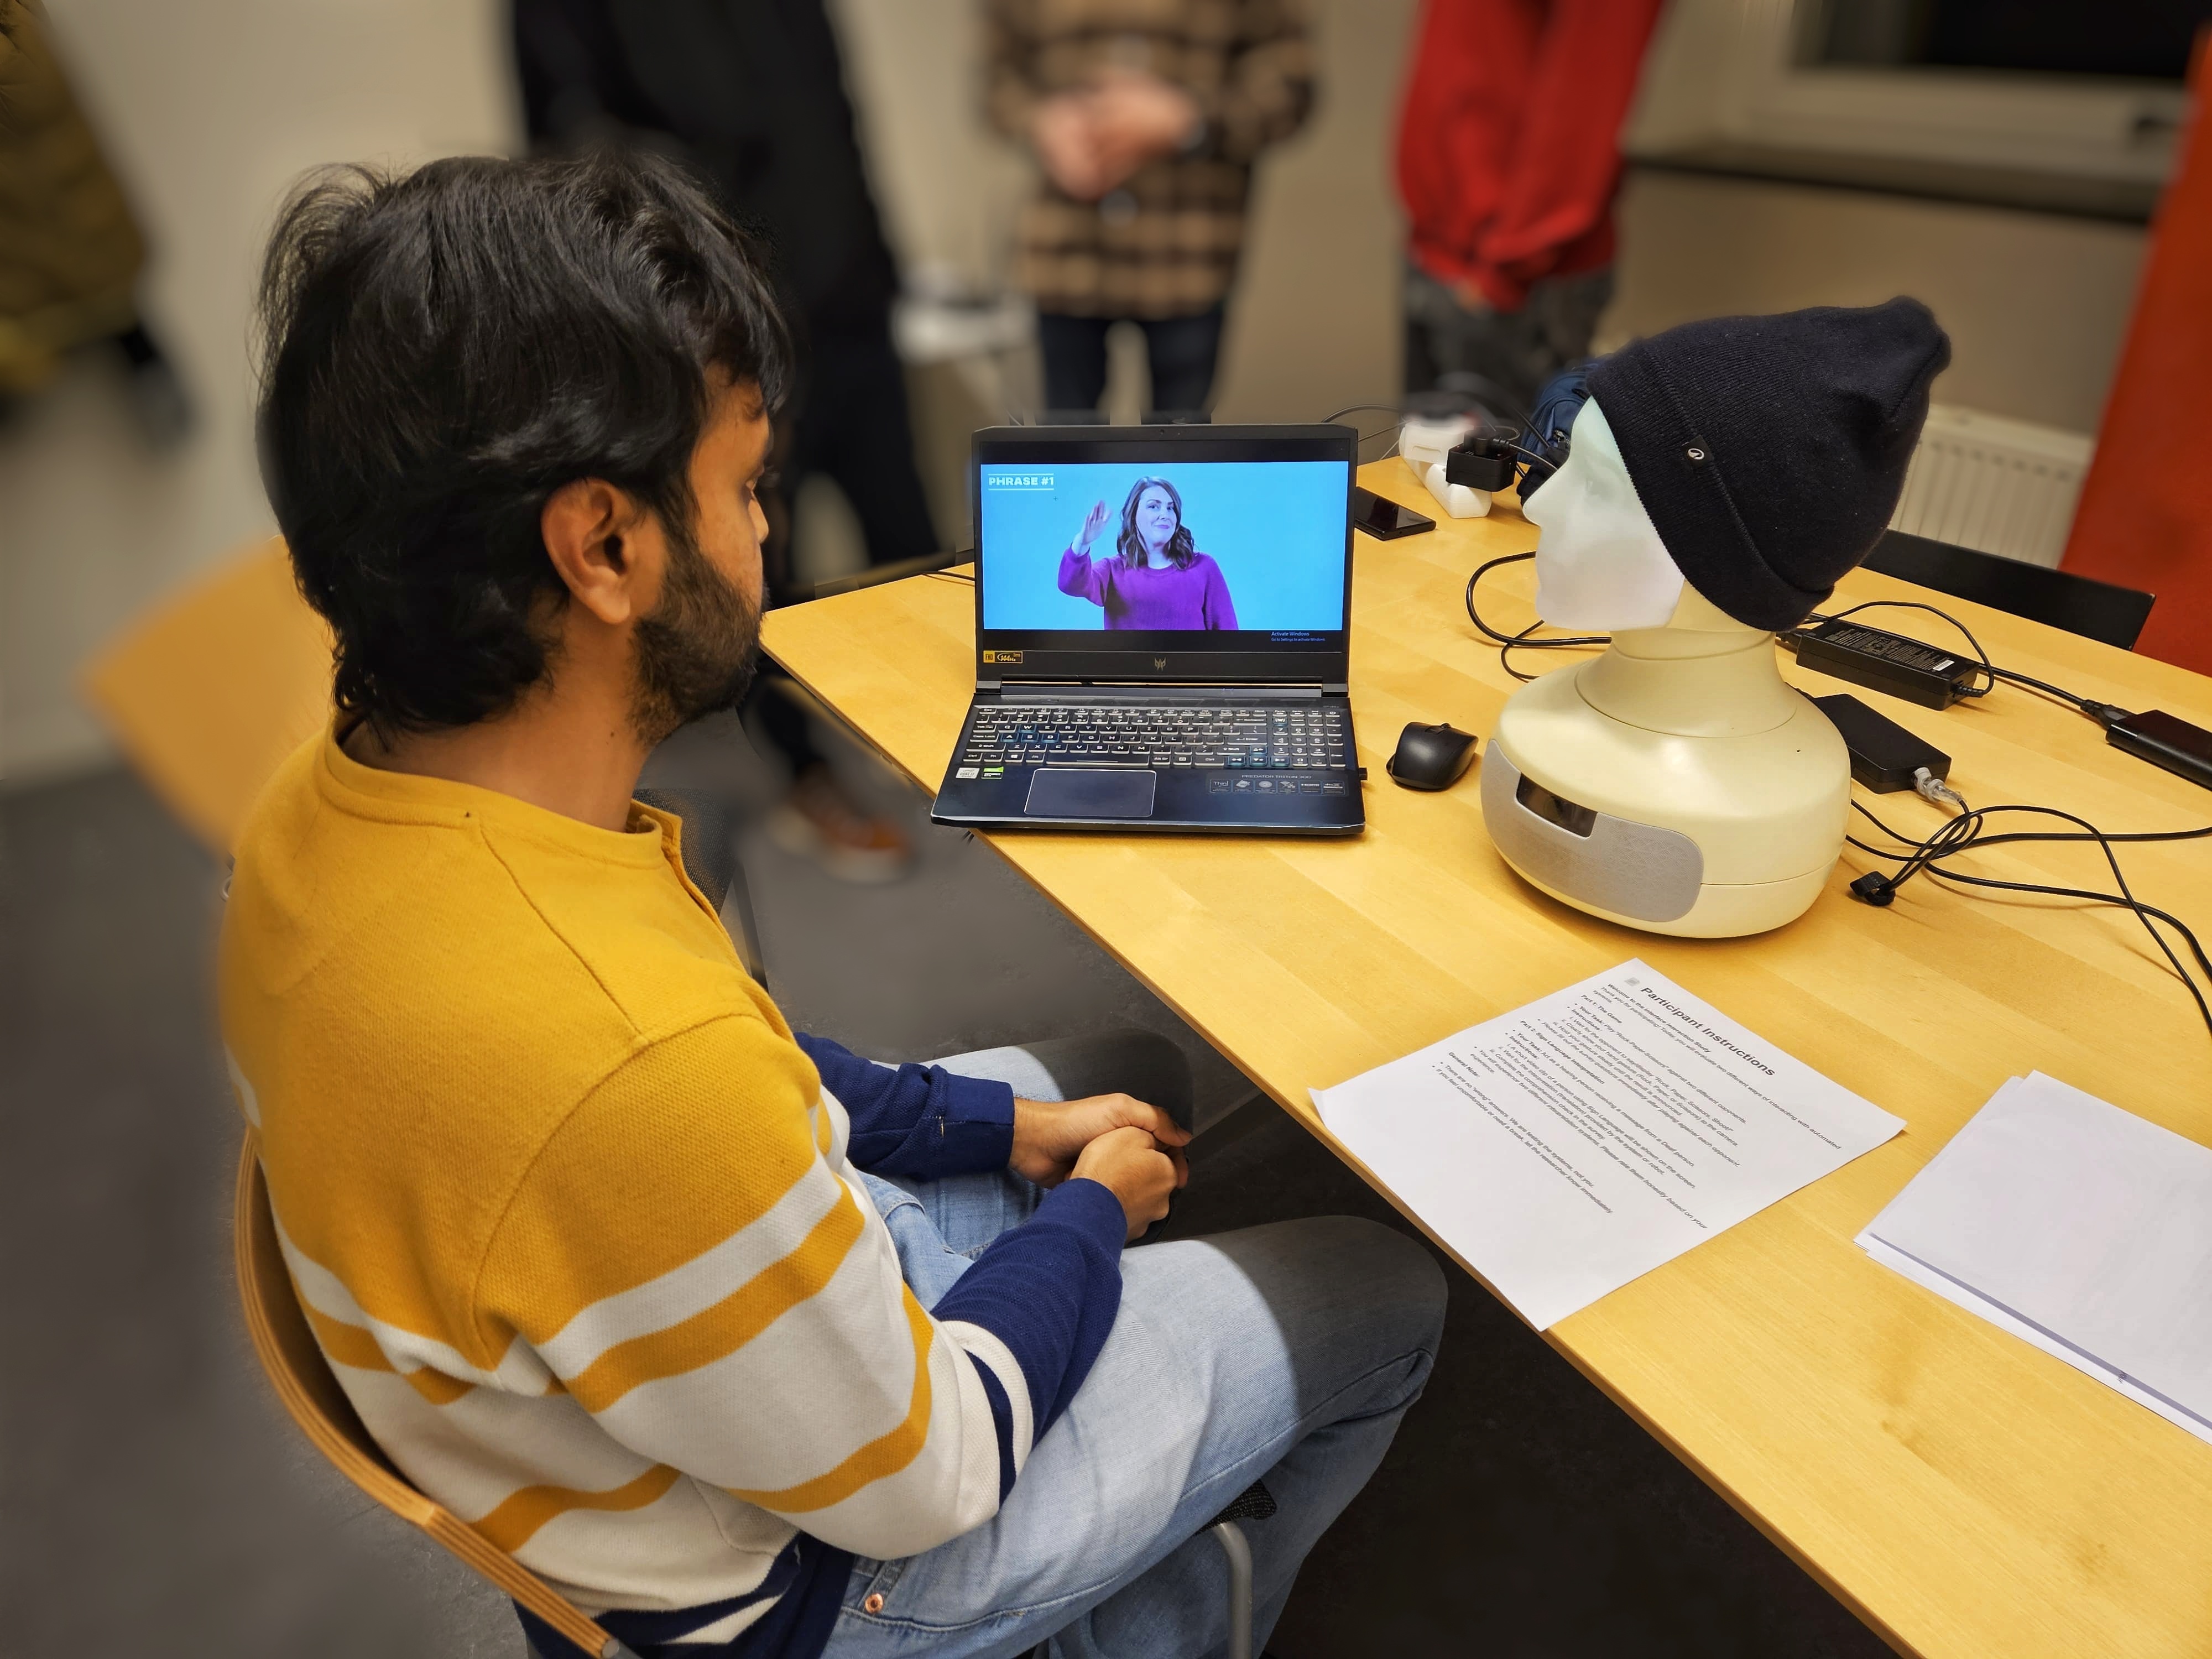
Embodied Robot for ASL Interpretation
A human-robot interaction study investigating how physical embodiment affects automated sign language interpretation. Pairs a Furhat social robot (dynamic gaze, facial expressions, synthesized speech) with a real-time OpenCV and MediaPipe 3D hand-tracking pipeline with temporal gesture filtering. A 26-participant within-subjects empirical study showed that physical embodiment significantly elevated user engagement (p < .001) and sociability without compromising comprehension or trust.
Project Details →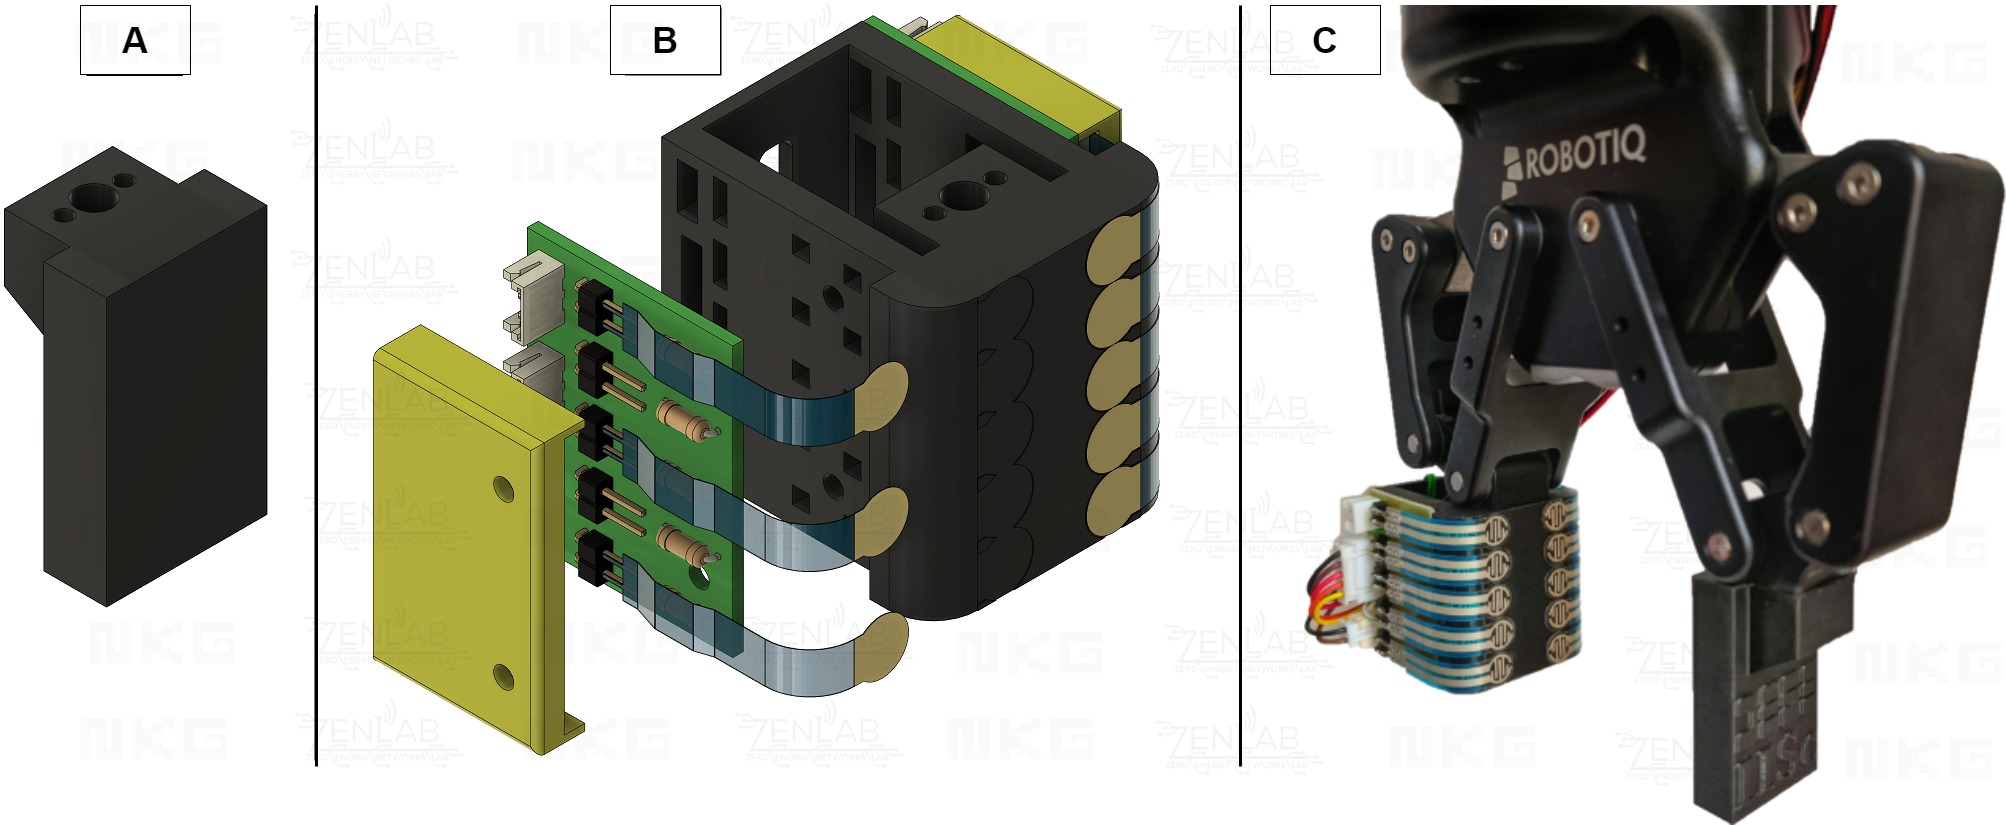
Custom Sensorized Gripper
Custom sensorized fingertips engineered for a Robotiq 2F-85 gripper on a UR3 arm, designed in Autodesk Fusion 360 and 3D printed. Houses a custom 5×3 force-sensitive resistor (FSR) array PCB with Arduino ADC acquisition to capture contact localization and grip force distribution during laparoscopic tool manipulation. Delivers real-time tactile telemetry back to operator haptic interfaces, preventing slippage and excessive clamping forces during teleoperated surgical tasks.
View Details →
Adaptive IoT Data Management
A Boeing-funded anomaly assessment and adaptive telemetry pipeline for aircraft cabin environmental control systems (ECS). Combines multi-zone MATLAB/Simulink physical simulations with supervised machine learning to classify sensor anomalies and assess severity across multivariate time series. Implements an error-bounded linear interpolation algorithm on the TICK stack, dynamically optimizing compression against reconstruction fidelity to achieve 96.6% storage savings.
Project Details →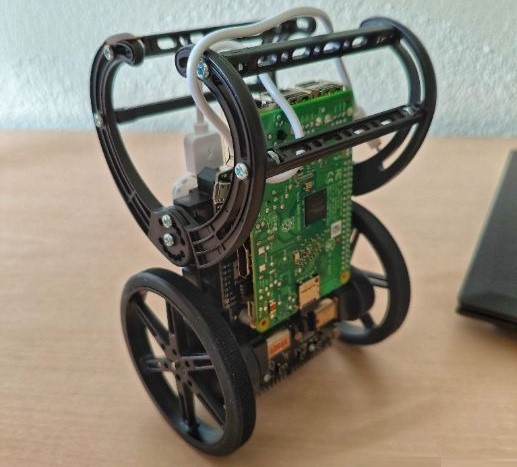
BalanceBot
A dynamic modeling and embedded control deployment pipeline for the Sigi two-wheeled inverted pendulum robot. Derived nonlinear 1-DOF and 2-DOF equations of motion in MATLAB/Simulink using Lagrangian mechanics, identified motor constants, and resolved encoder overflow. Designed and benchmarked PID, Phase-Lead, and LQR controllers, deploying C code to an onboard Raspberry Pi 3B+ via Simulink External Mode over I2C to evaluate sim-to-real transfer, actuator saturation, and gearbox backlash.
Code → Project Details →View archive of all projects →
Publications
Education
- Master of Science in Autonomous Systems and Intelligent Robots — EIT Digital Master School (2026)
- KTH Royal Institute of Technology, Sweden
- Polytech Nice Sophia, Université Côte d'Azur, France
- Bachelor of Technology in Mechanical Engineering — National Institute of Technology Karnataka (NITK), India (2017)
Experience
- Master's Thesis & Summer Worker, Vehicle Data and Driver Support — Scania (TRATON Group), Sweden (2026)
- Technical Associate & Researcher — Indian Institute of Science (IISc), Bangalore (2019–2024)
- Centre for Networked Intelligence (CNI) • 2022–2024
- Research Associate, Dept. of Electronic Systems Engineering (DESE) • 2021–2024
- Research Assistant, DESE • 2019–2021
- Team Leader, Maintenance — Hindustan Coca-Cola Beverages Pvt. Ltd. (2017–2018)
Awards & Achievements
- Best Paper Award – CNERT 2024 — IEEE INFOCOM
- First Place – 5G Hackathon 2020 — Government of India (Team 5G-AMMAZING, $7,200 award)